Embedded Systems · FPGA/HDL · Robotics

Vineet
Sharma

Electronics Engineer

I am an Electronics and Communication Engineering student passionate about robotics, PCB design, VLSI, and FPGA-based systems. As an active member of SRM Team Robocon, I have gained hands-on experience in robot design, embedded systems, and hardware development. I have also worked on Unmanned Ground Vehicles (UGVs) and e-Yantra robotics projects, exploring the integration of electronics, control systems, and intelligent automation. I aim to develop innovative hardware solutions by combining electronics, robotics, and digital design.

Vineet Sharma
FPGA / Verilog HDL Embedded C/C++ PCB Design (Altium) BLDC / FOC Motor Control Teensy · Arduino · ESP32 I2C / SPI / UART RF Telemetry Power Electronics
← All Projects
// Defence Robotics · Indian Army

UGV A/T

Anti-Tank Mine Laying System

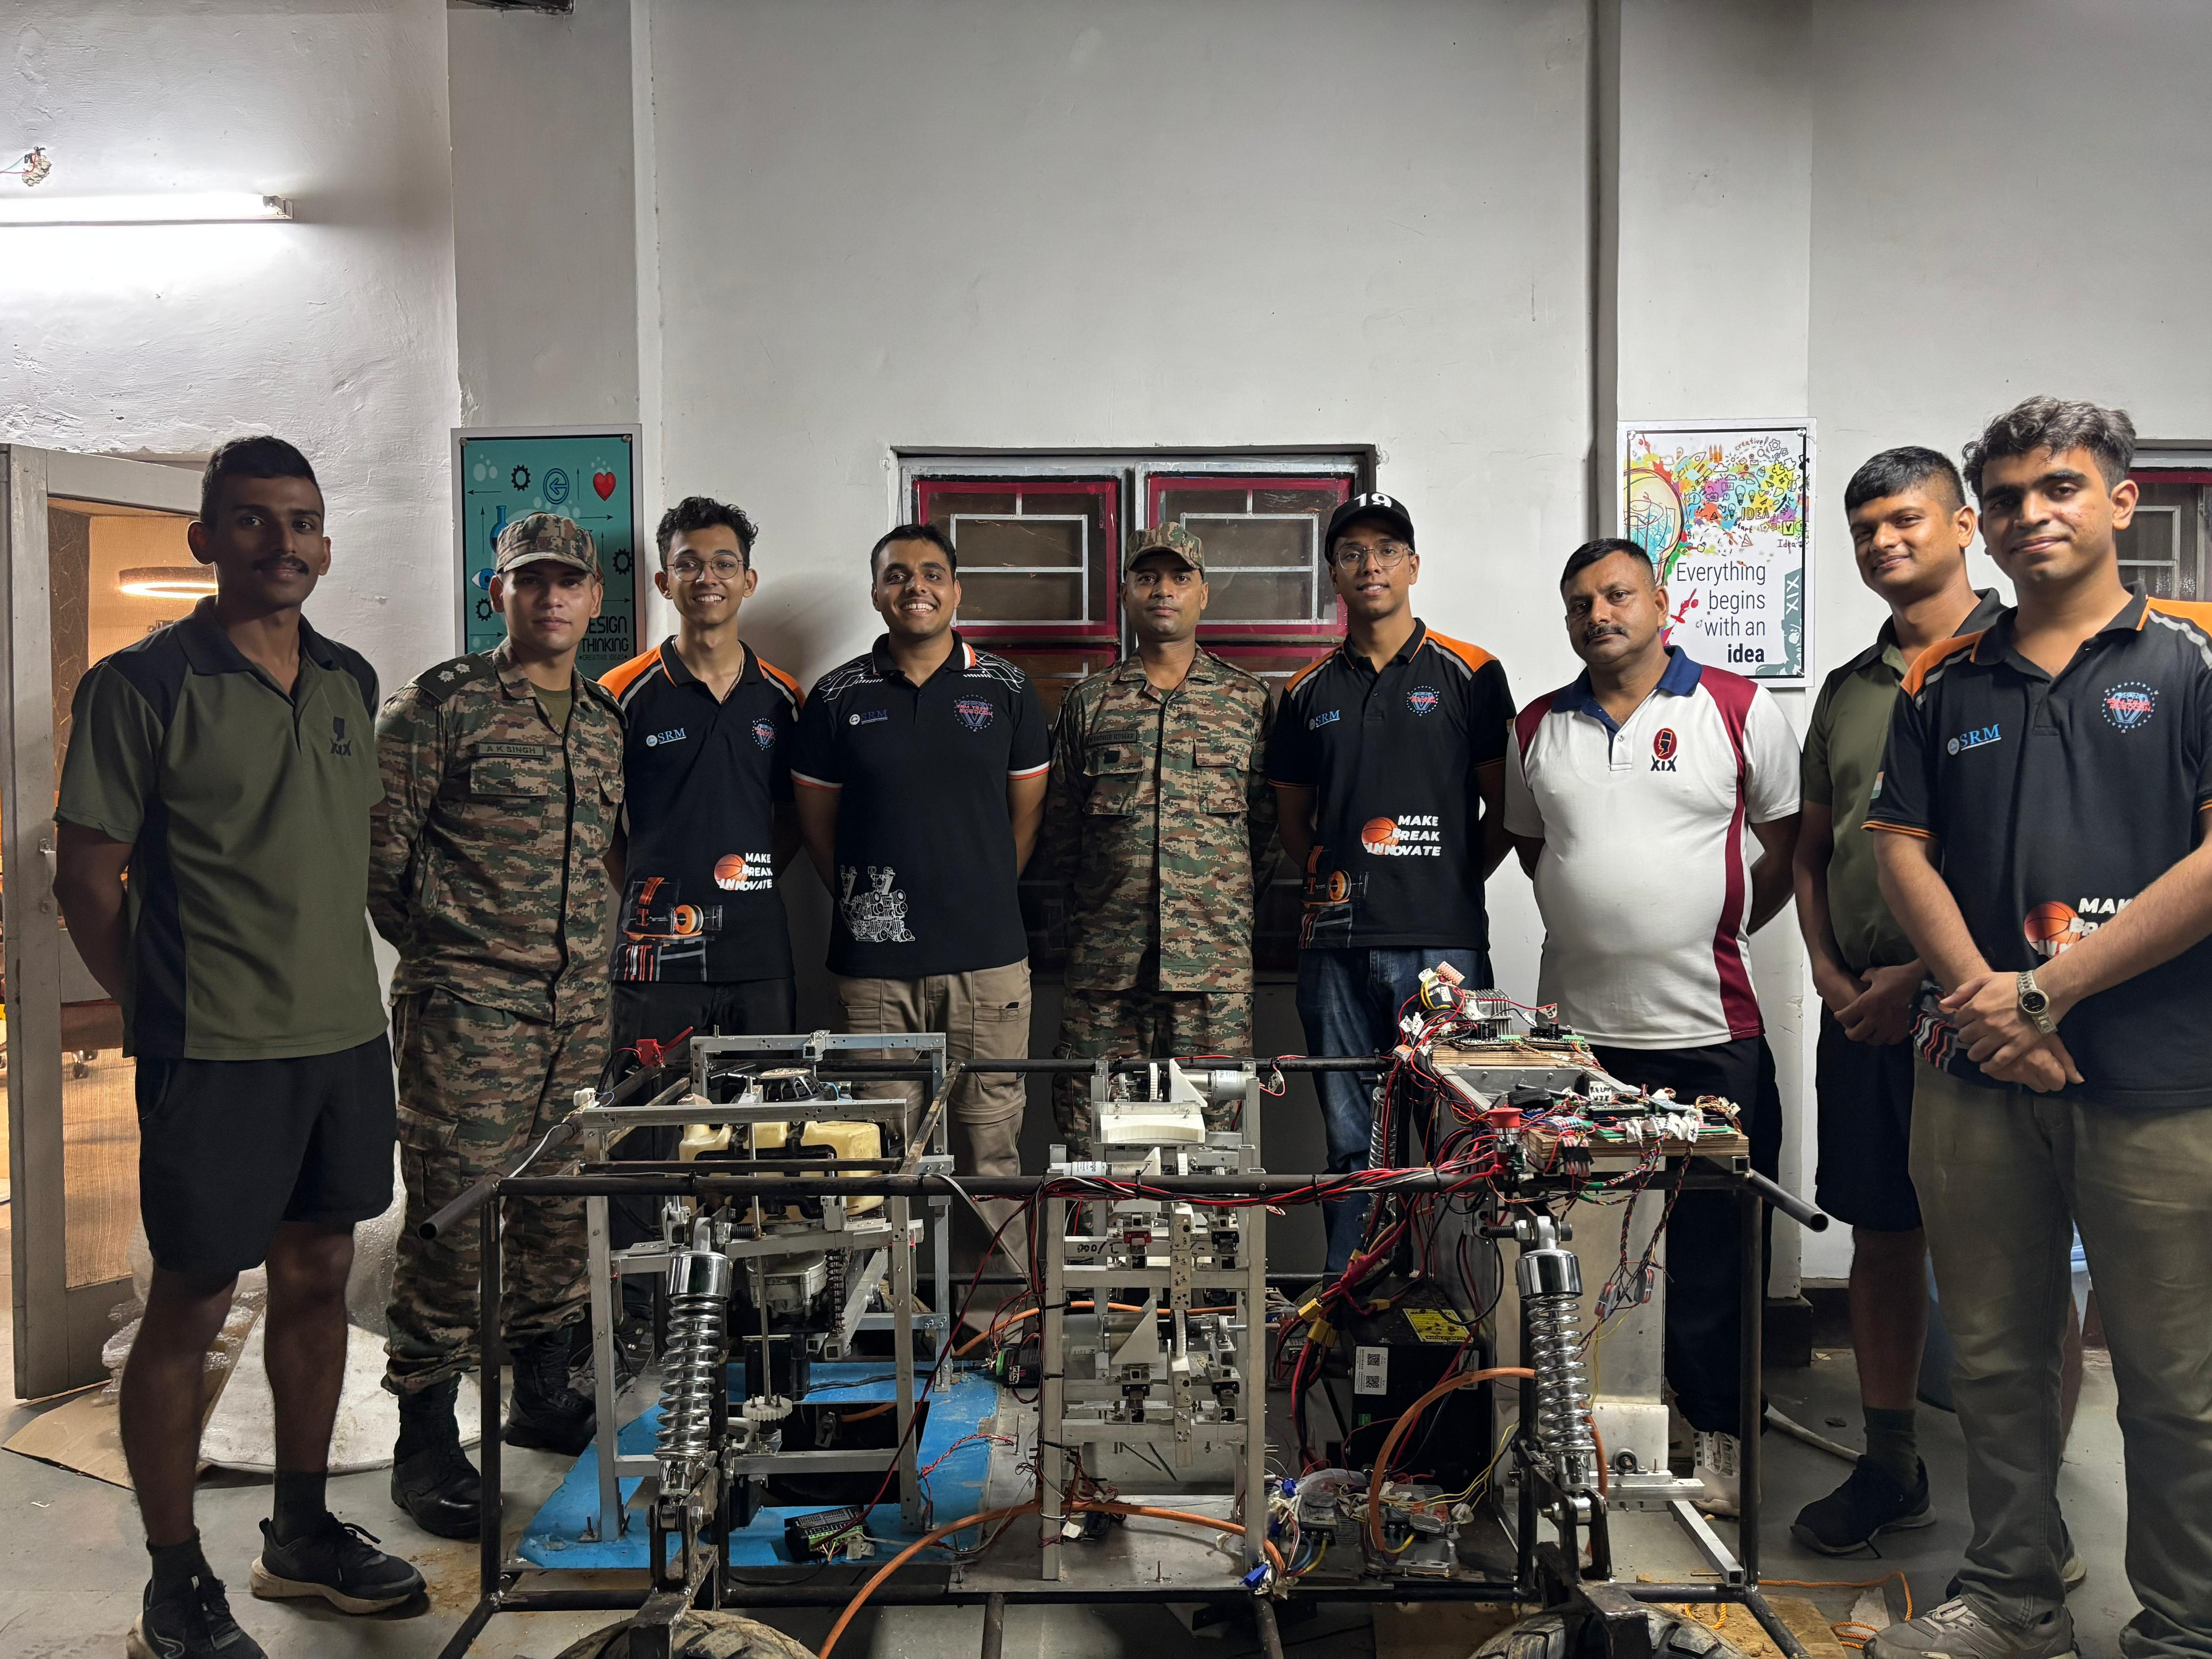
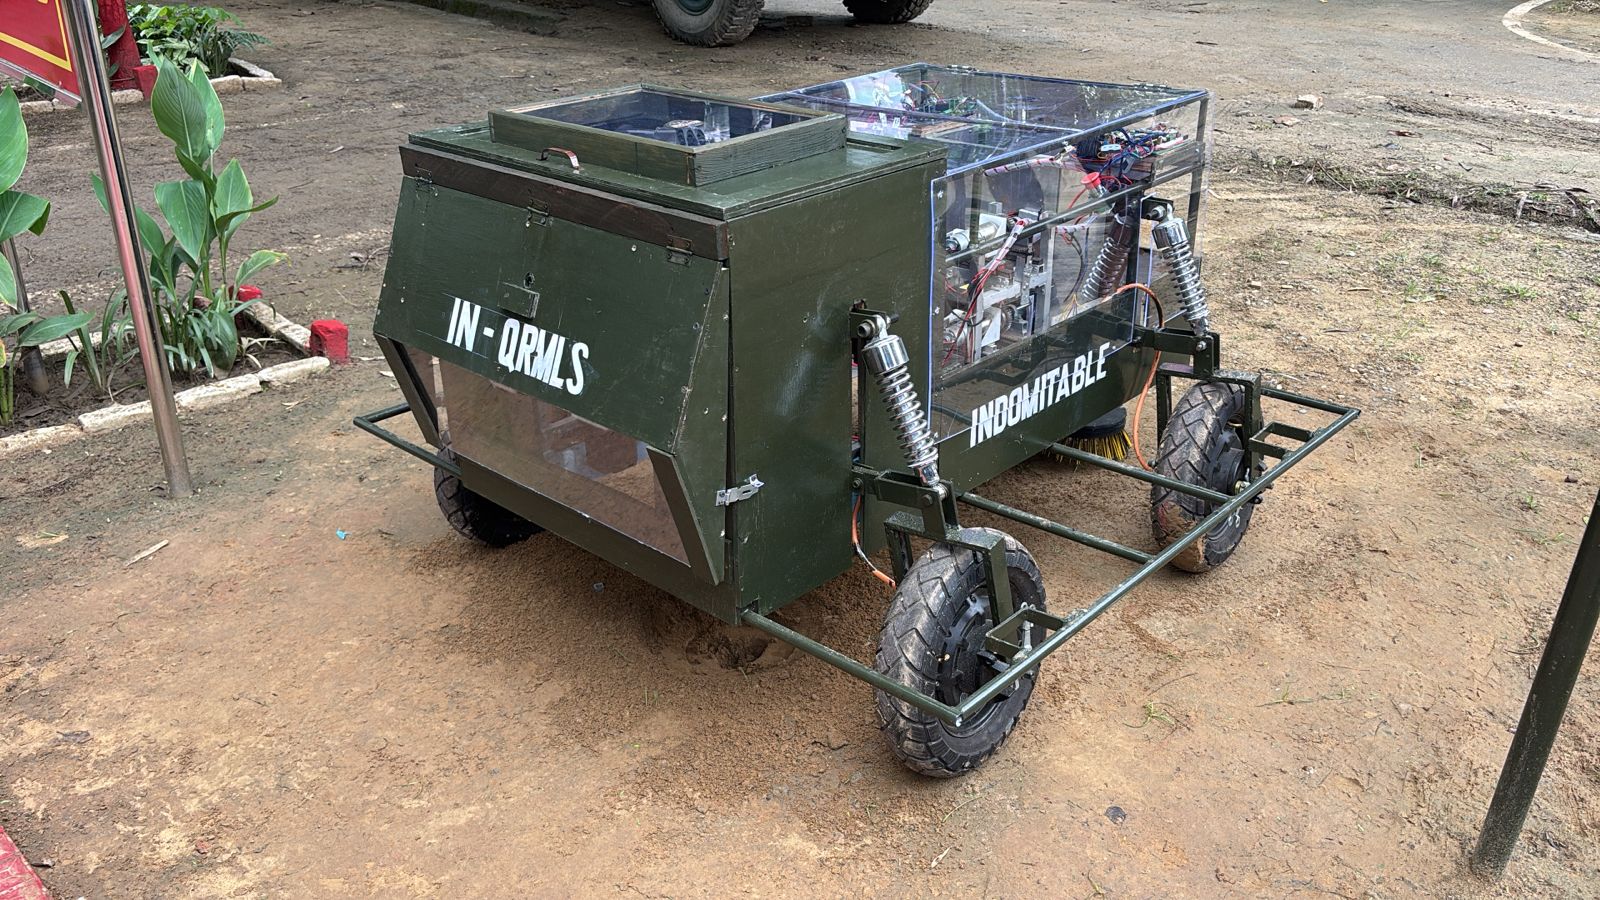
Semi-autonomous UGV built with the 19 Engineer Regiment for automated excavation and precision mine placement, keeping soldiers out of danger. Field-tested in sub-zero, high-altitude conditions.
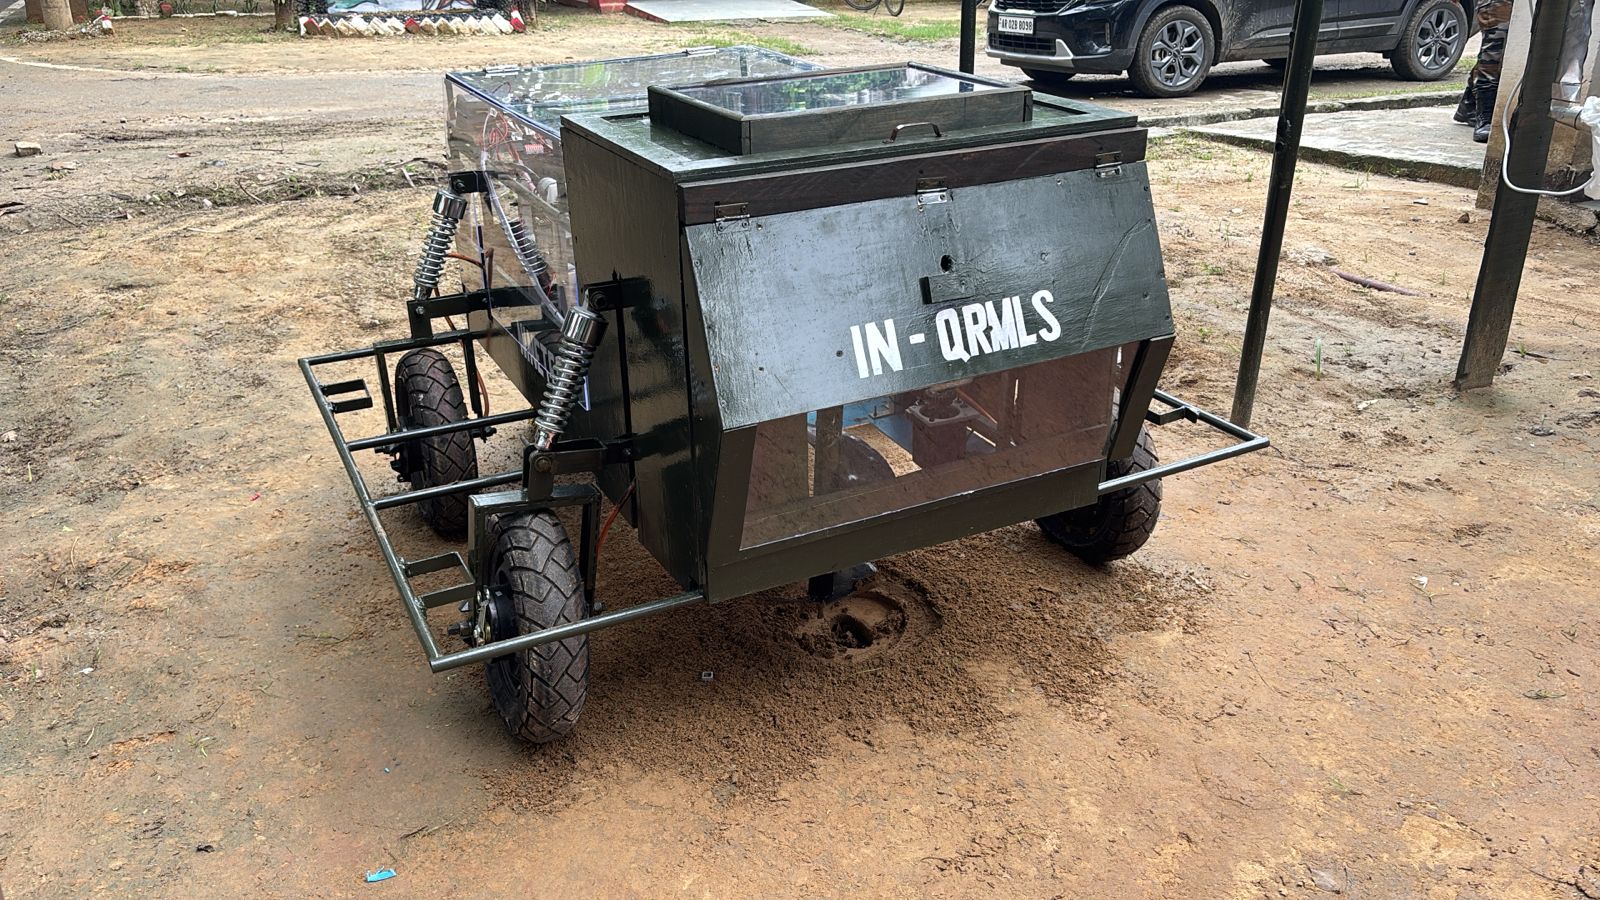
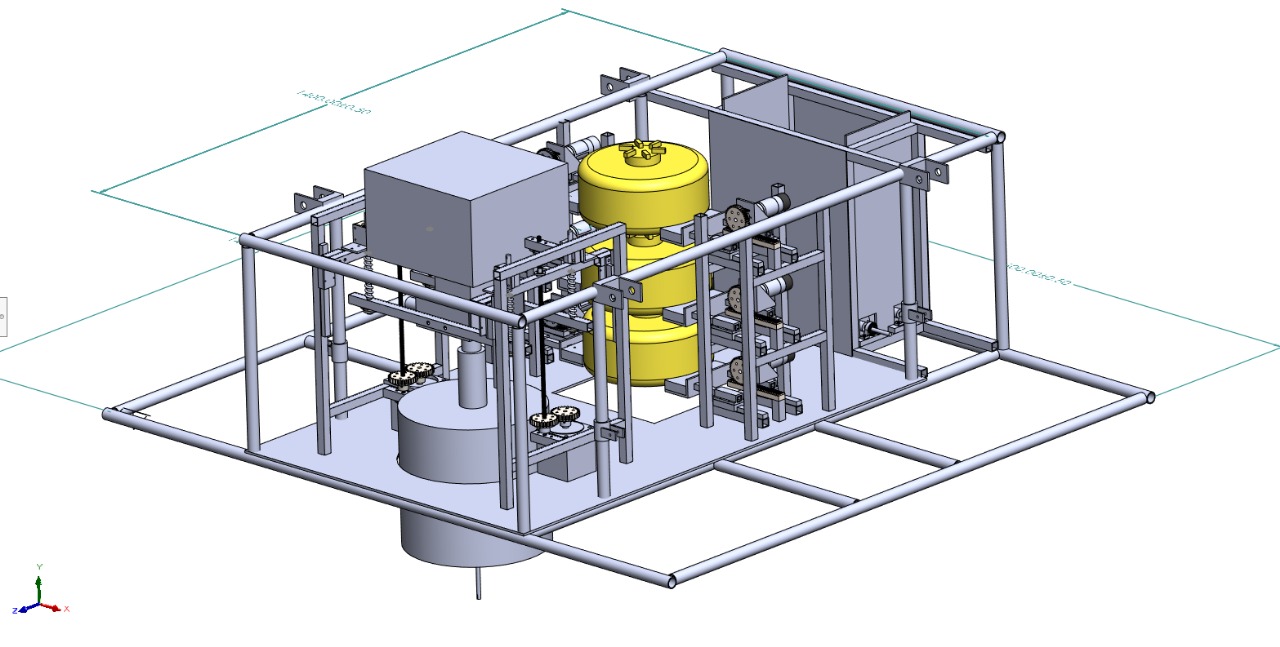
★ Top 30 of 260+ entries — Northern Command Inno Yodha 2025–26
// My Role — Embedded Systems Lead
  • Designed the control architecture around Teensy 4.1 and a custom interface board
  • Built the 4-wheel BLDC hub-motor drive with per-wheel ESC control
  • Integrated 433 MHz telemetry (300–500 m) and 5.8 GHz FPV video
  • Designed and fabricated interface/power PCBs in-house
  • Managed the 13S LiFePO4 power system and led field testing at the army unit
// Stack
Teensy 4.1BLDC Hub Motors433 MHz Telemetry 5.8 GHz FPVNema 34 + TB660013S LiFePO4 Custom PCB
← All Projects
// FPGA Robotics · IIT Bombay

MazeSolver Bot

e-Yantra Robotics Competition 2025–26

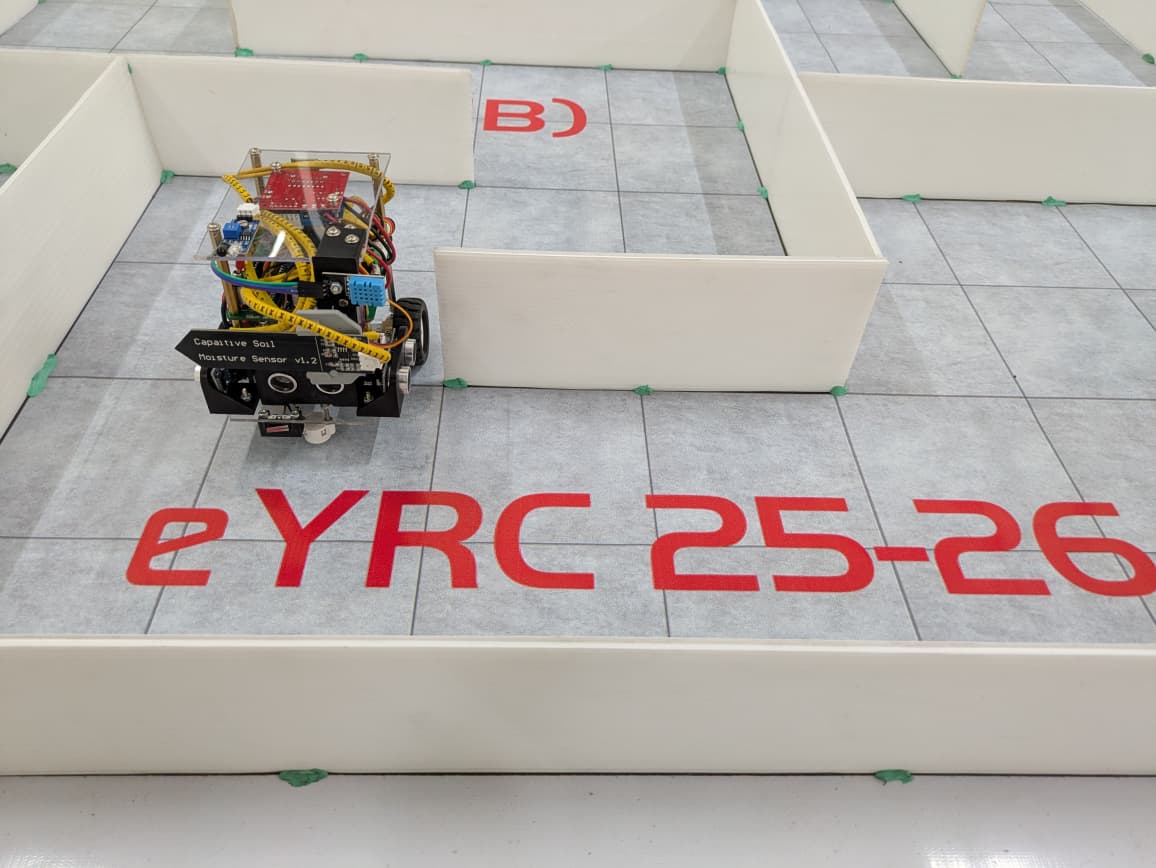
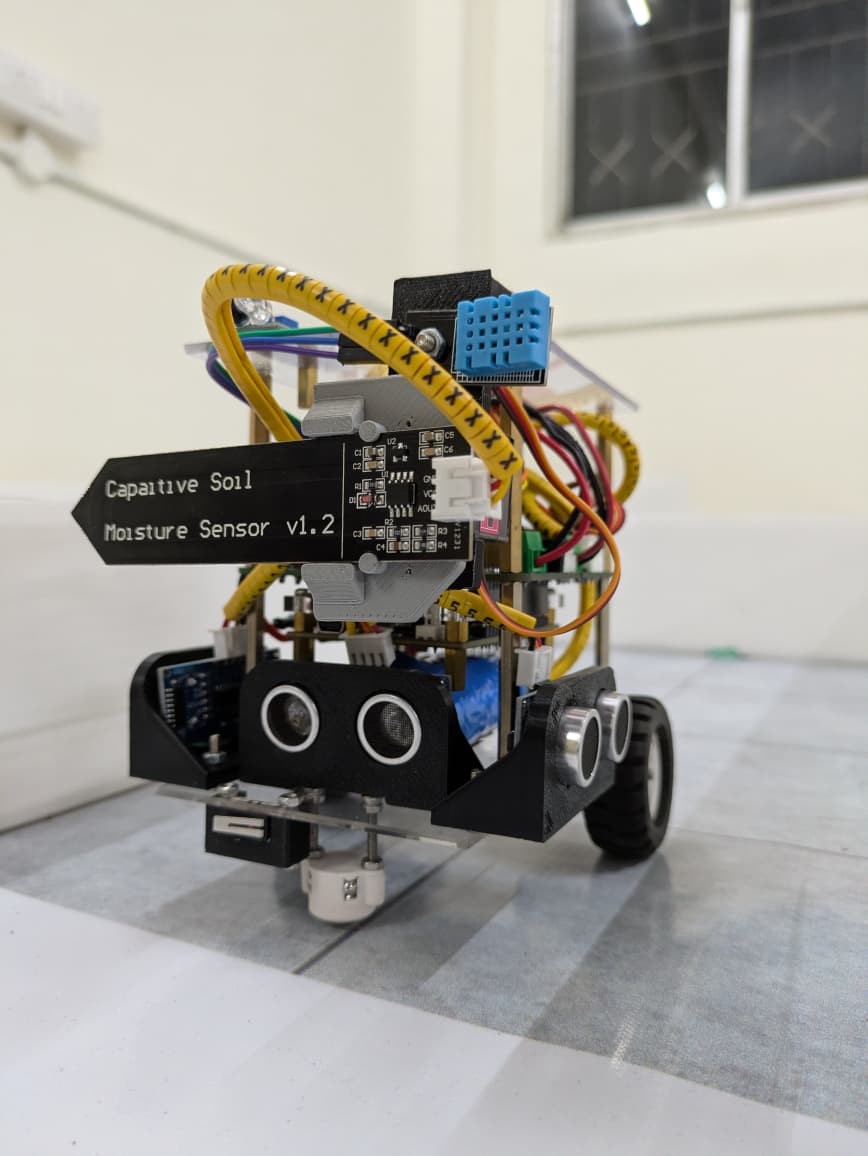
FPGA-powered autonomous robot on a De0-Nano (Cyclone IV) that navigates dynamic mazes in real time while sensing temperature, humidity and soil moisture — all in parallel hardware logic.
★ Top 50 nationally — eYRC 2025–26 · Level 3 Certificate, IIT Bombay
// My Role — FPGA Systems & Firmware
  • Designed a custom CPU core in Verilog on Cyclone IV fabric
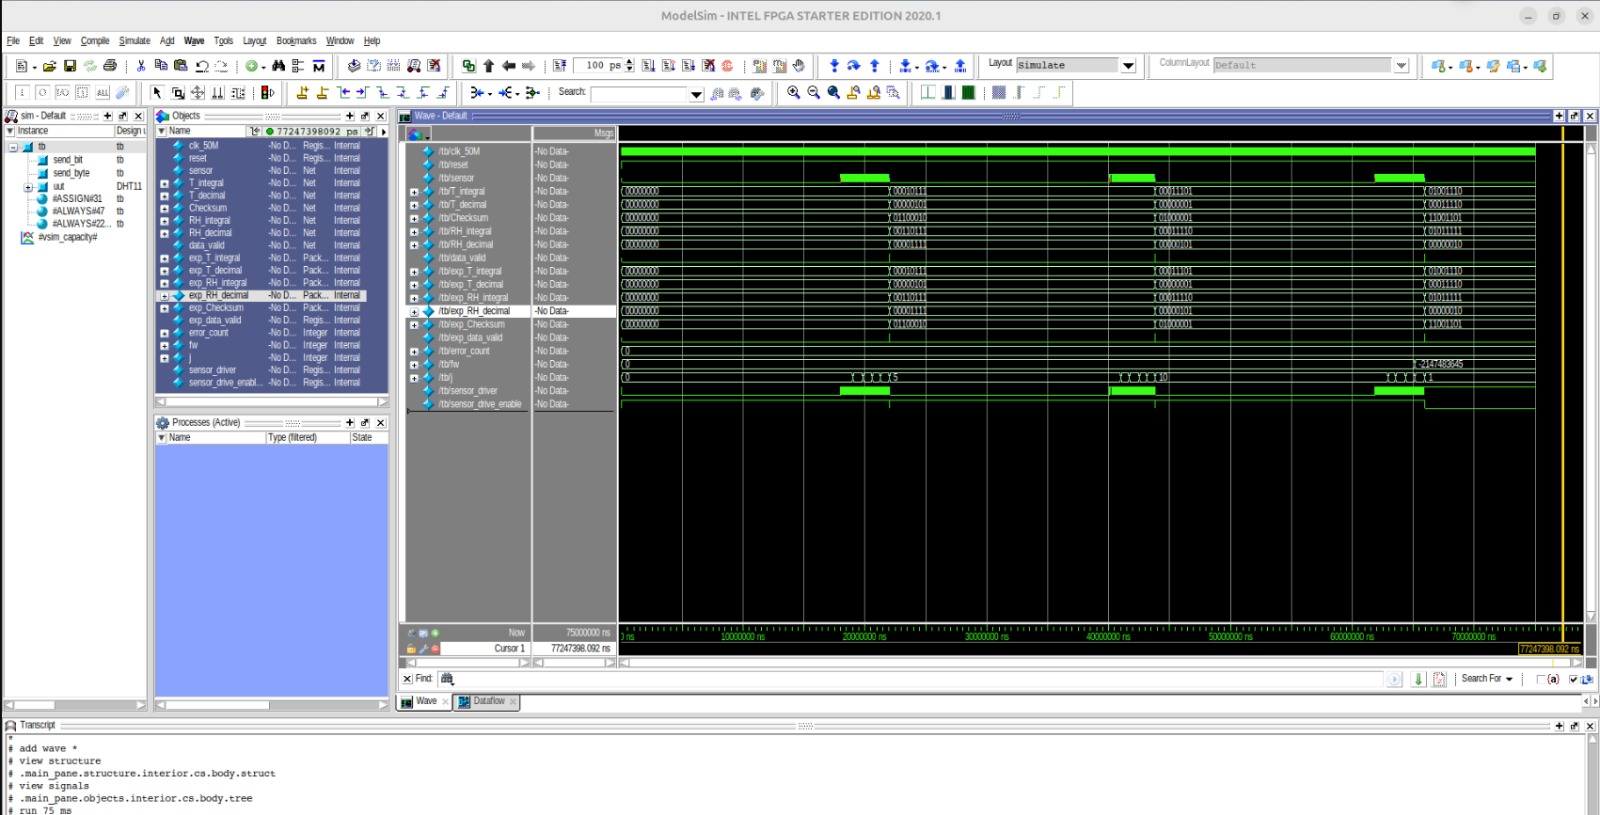
  • Wrote DHT11, HC-SR04 and UART drivers in Verilog, verified in ModelSim
  • Built a parallel architecture — sensing, motor FSM, maze logic and UART run concurrently as hardware
  • Developed a real-time maze-solving FSM that adapts to reconfigured arenas
// Stack
Verilog HDLDe0-Nano · Cyclone IVModelSim Custom CPUFSM DesignUART DHT11 · HC-SR04
← All Projects
// Robotics Competition · IIT Delhi

DD Robocon 2025

Basketball Bots · National Robotics Championship

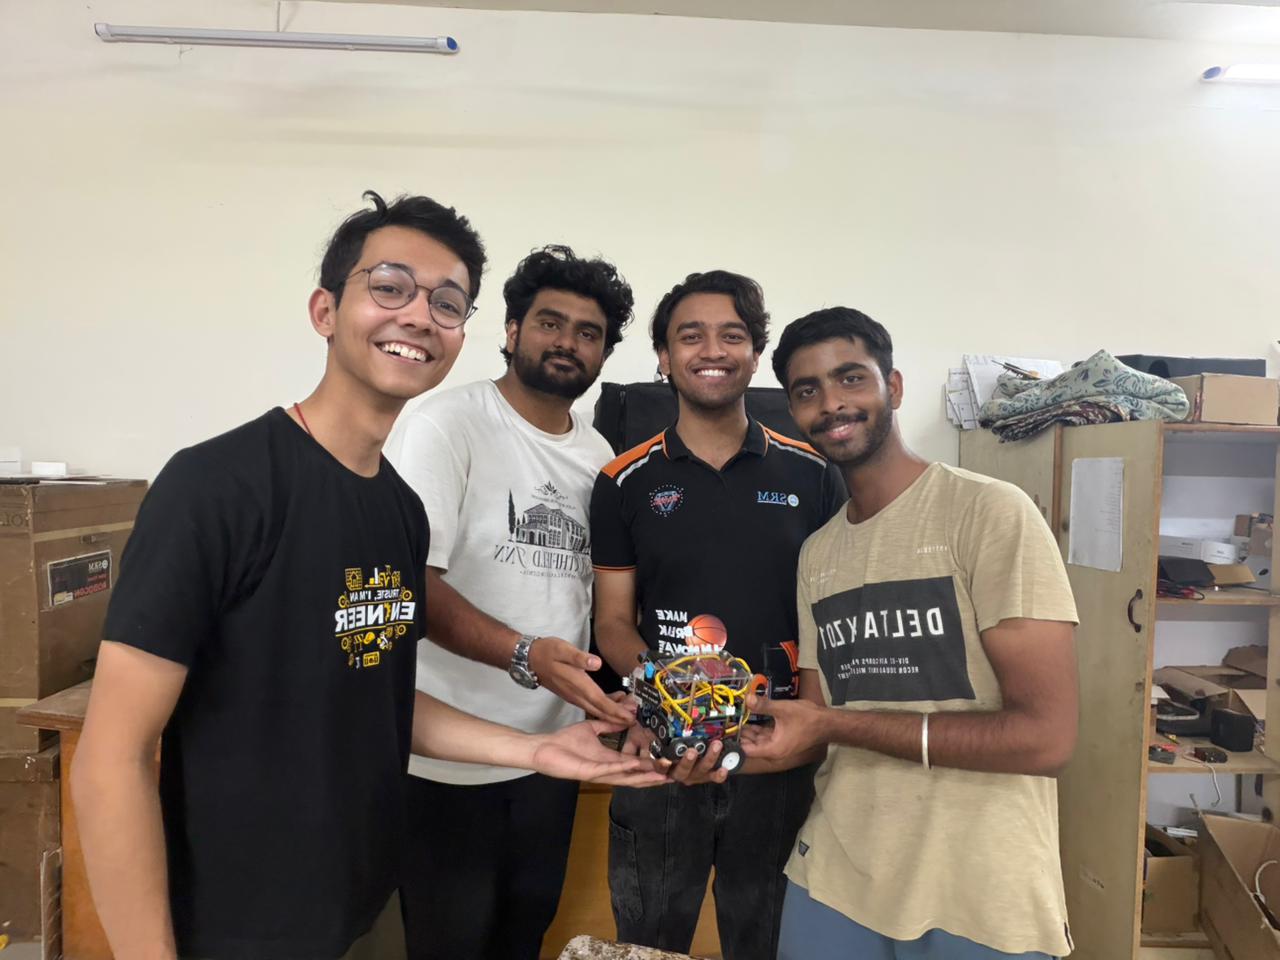
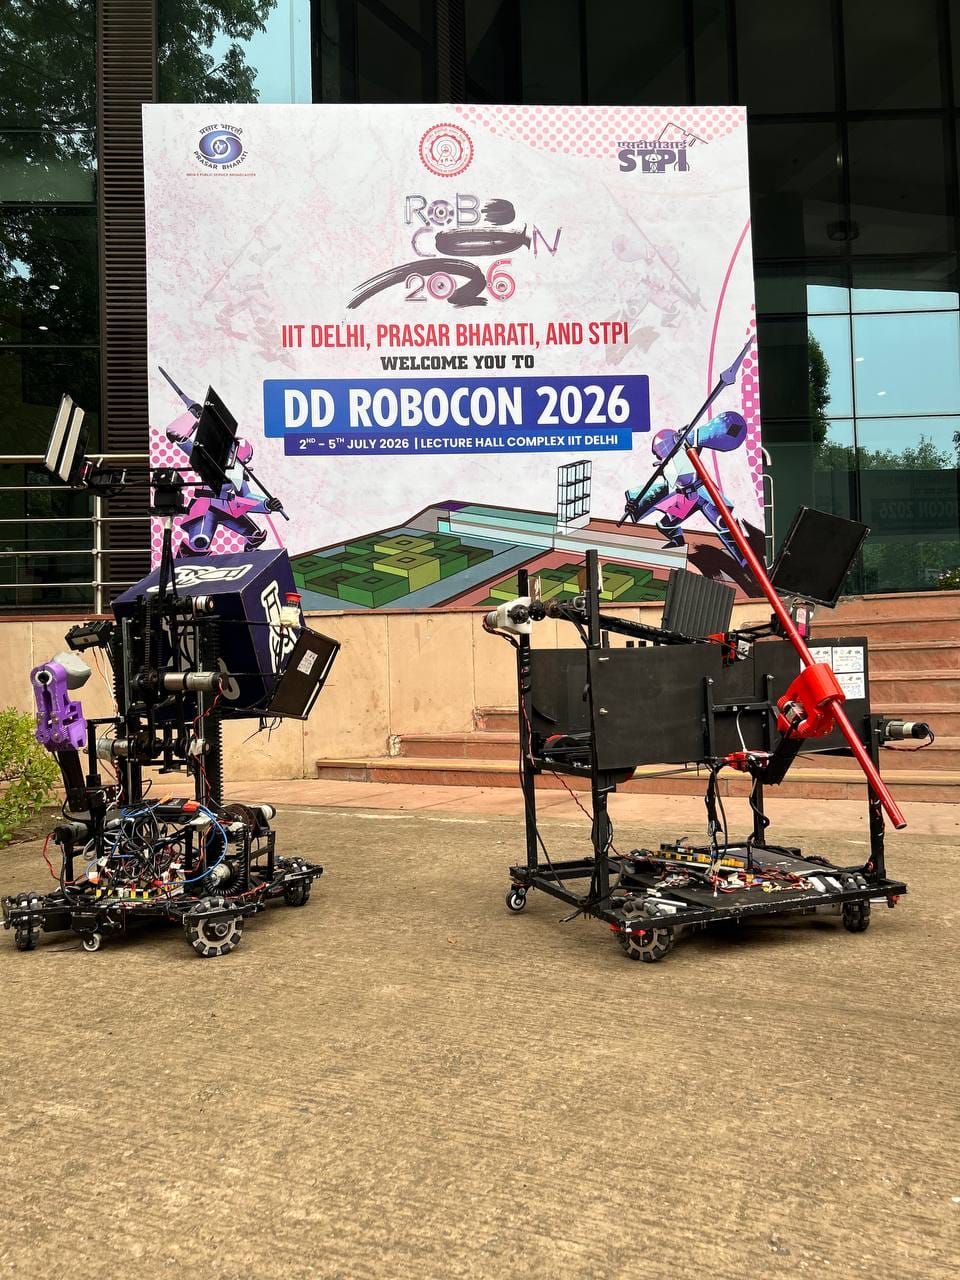
Two-robot basketball system for DD Robocon 2025 (ABU Robocon format). I worked on the electronics side — custom PCB and FOC-based BLDC motor control.
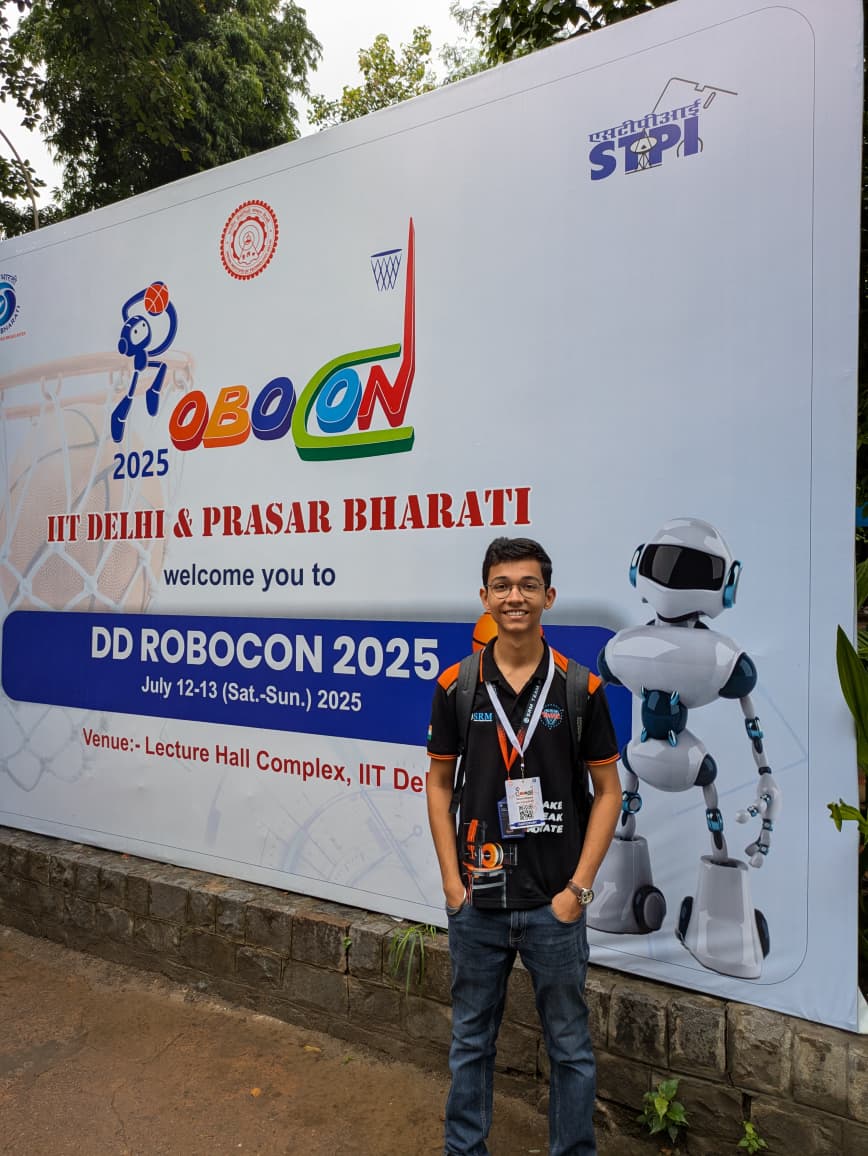
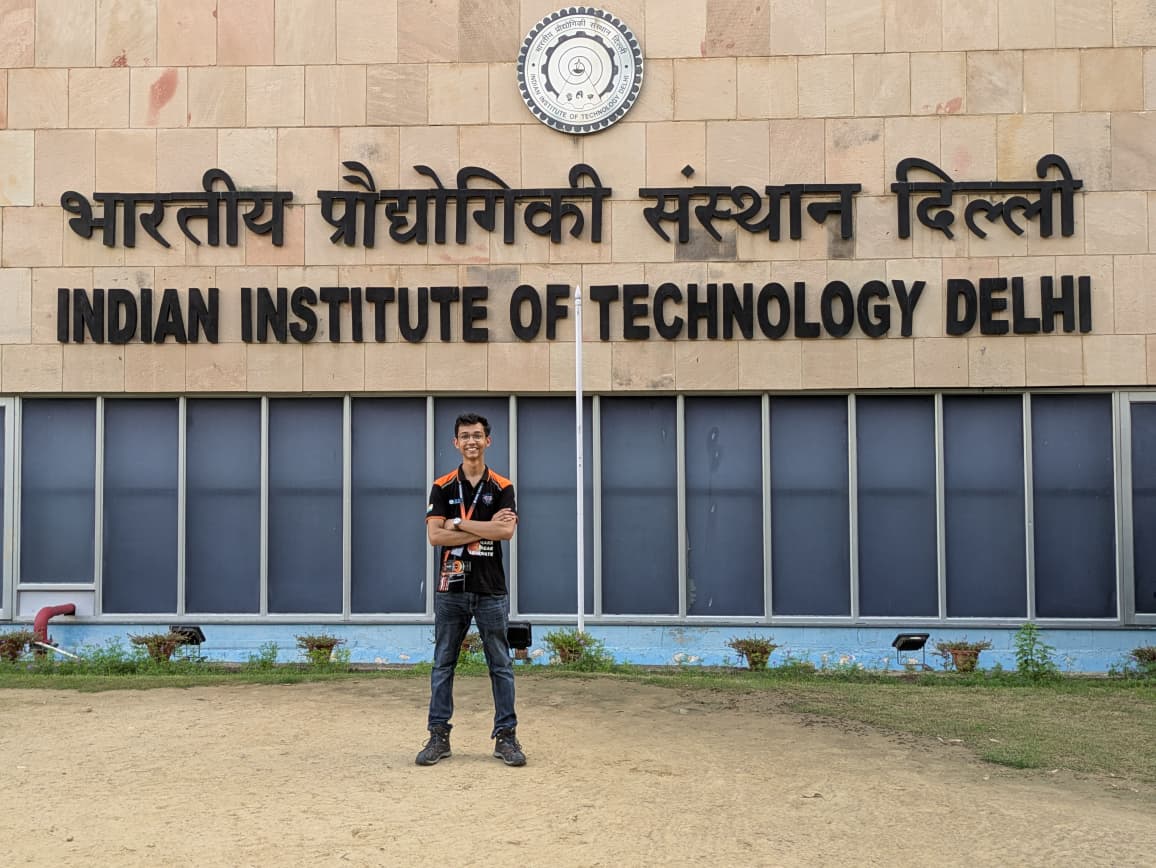
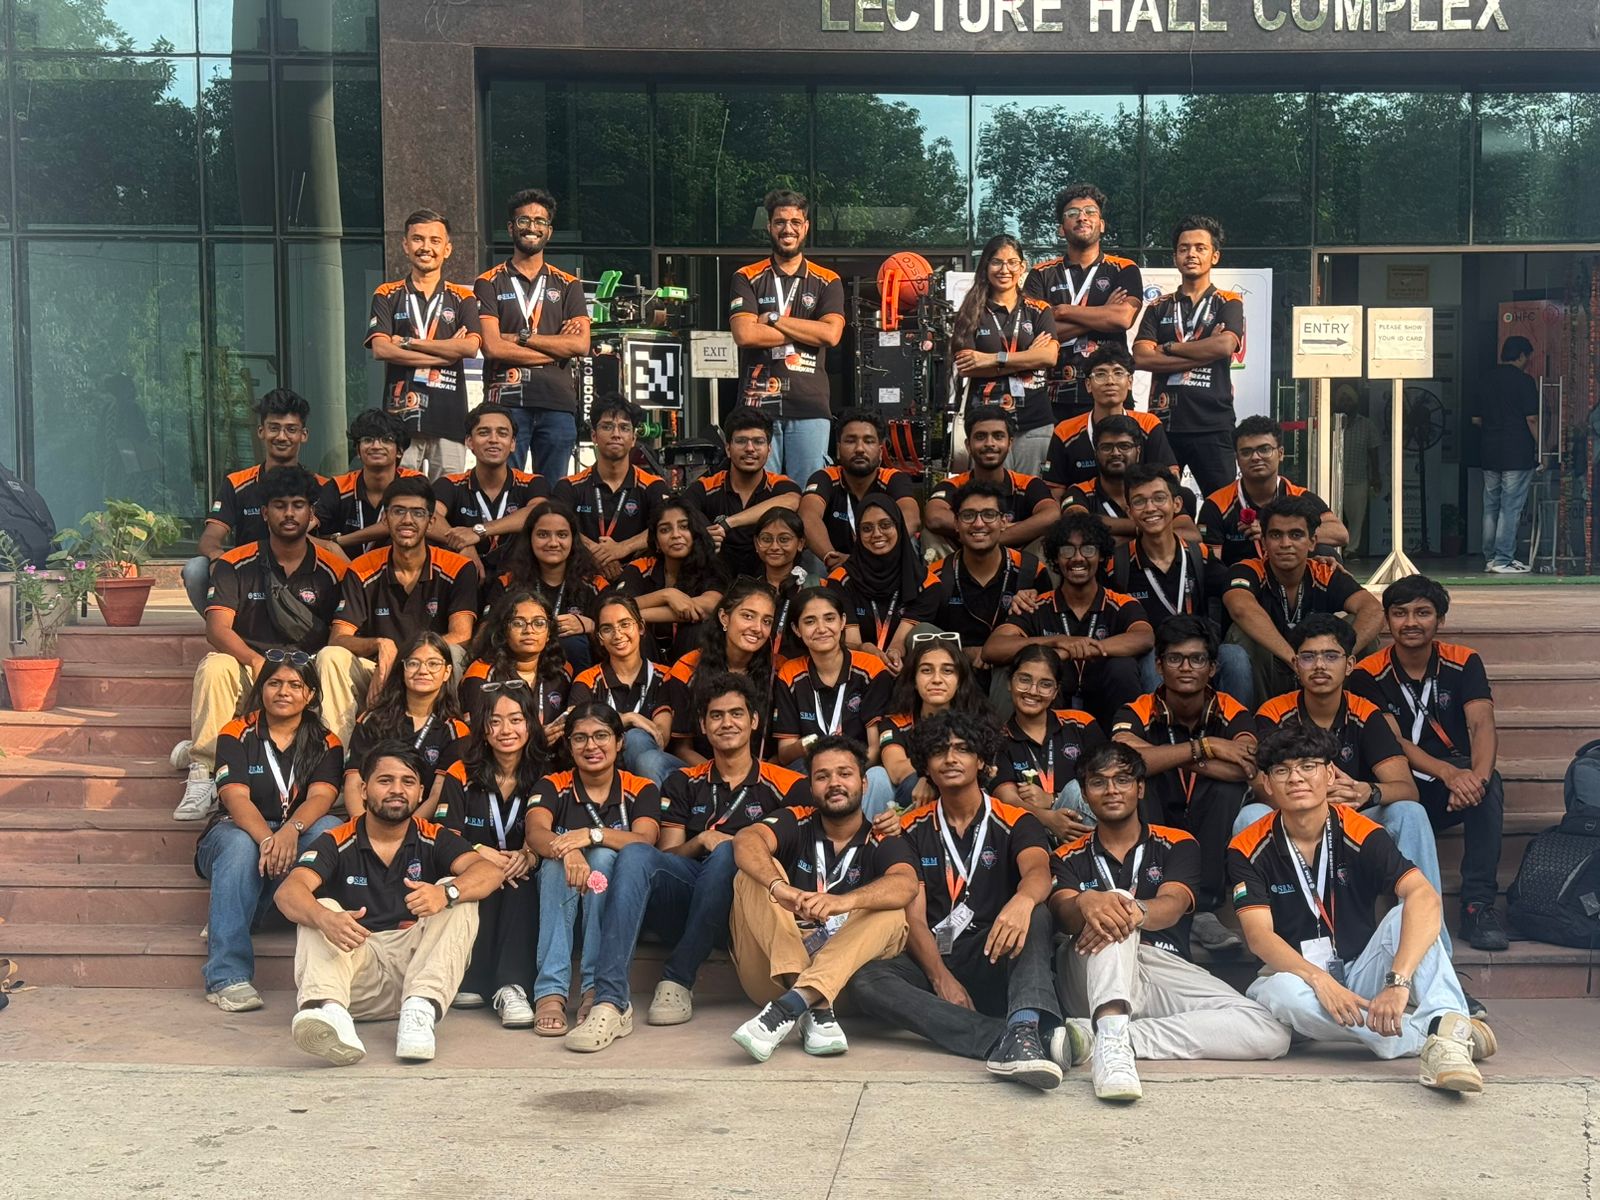
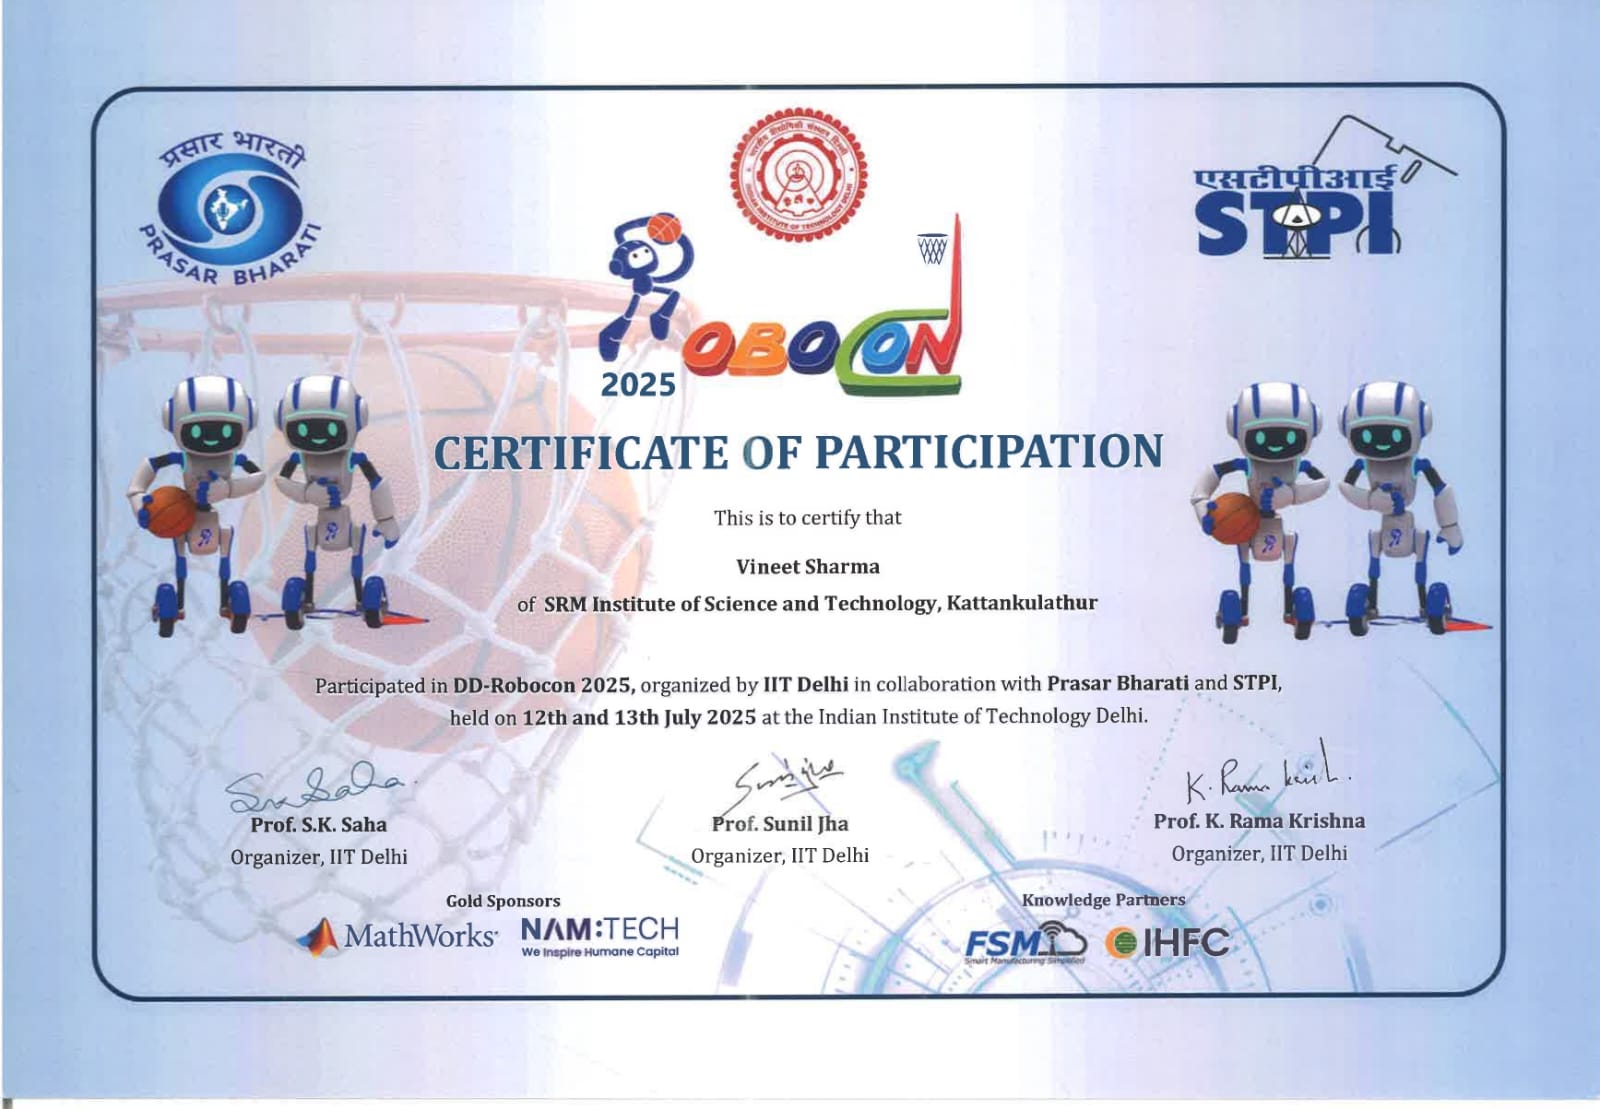
★ National finals · IIT Delhi · 40 student teams · 12–13 July 2025
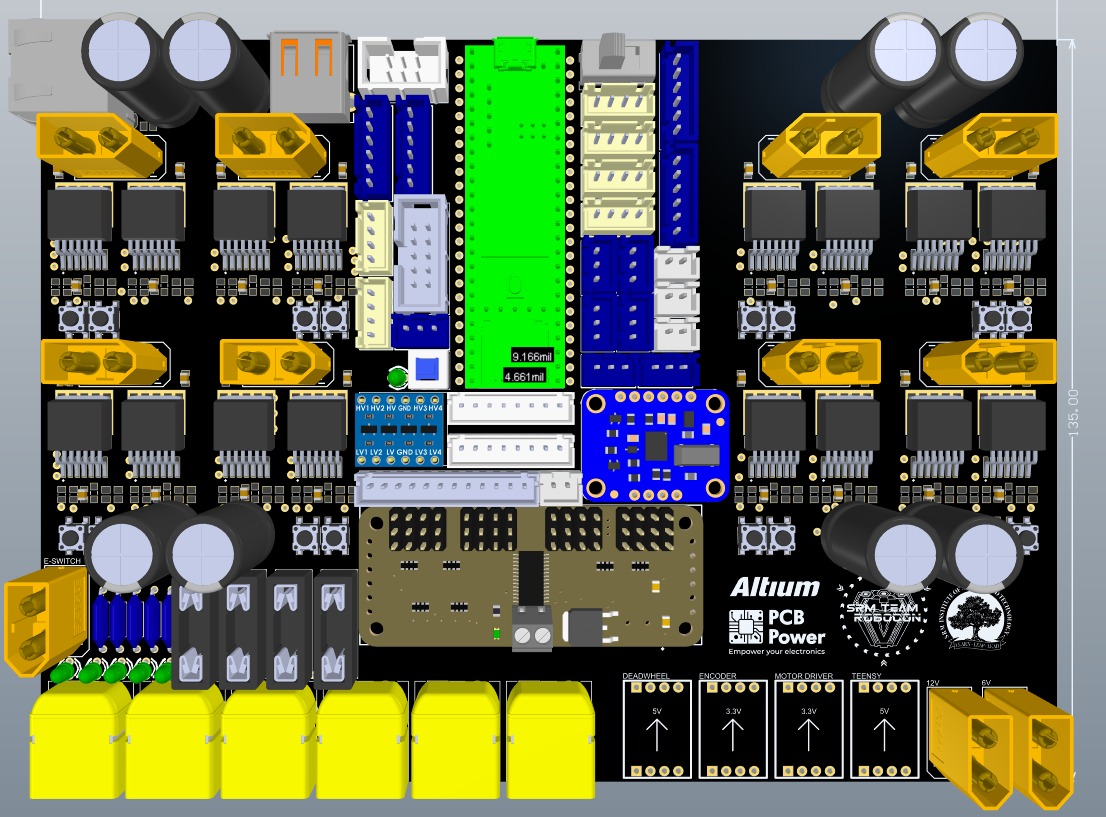
// Interactive 3D PCB — BOT1_2025
// Drag to rotate · scroll to zoom
Open Full Screen ↗
// My Role — Electronics & Embedded
  • Implemented Field-Oriented Control (FOC) on VESC ESCs driven by a Teensy MCU
  • Contributed to the custom PCB integrating controller, motor interfaces and support electronics
  • Developed and debugged the motor-control layer for reliable repeated runs on the competition floor
// Stack
TeensyVESCFOC BLDCEmbedded C/C++PCB Design
← All Projects
// 4-Layer PCB · DD Robocon 2026 · IIT Delhi

Actuator + Interface Board

Modular Robot Electronics

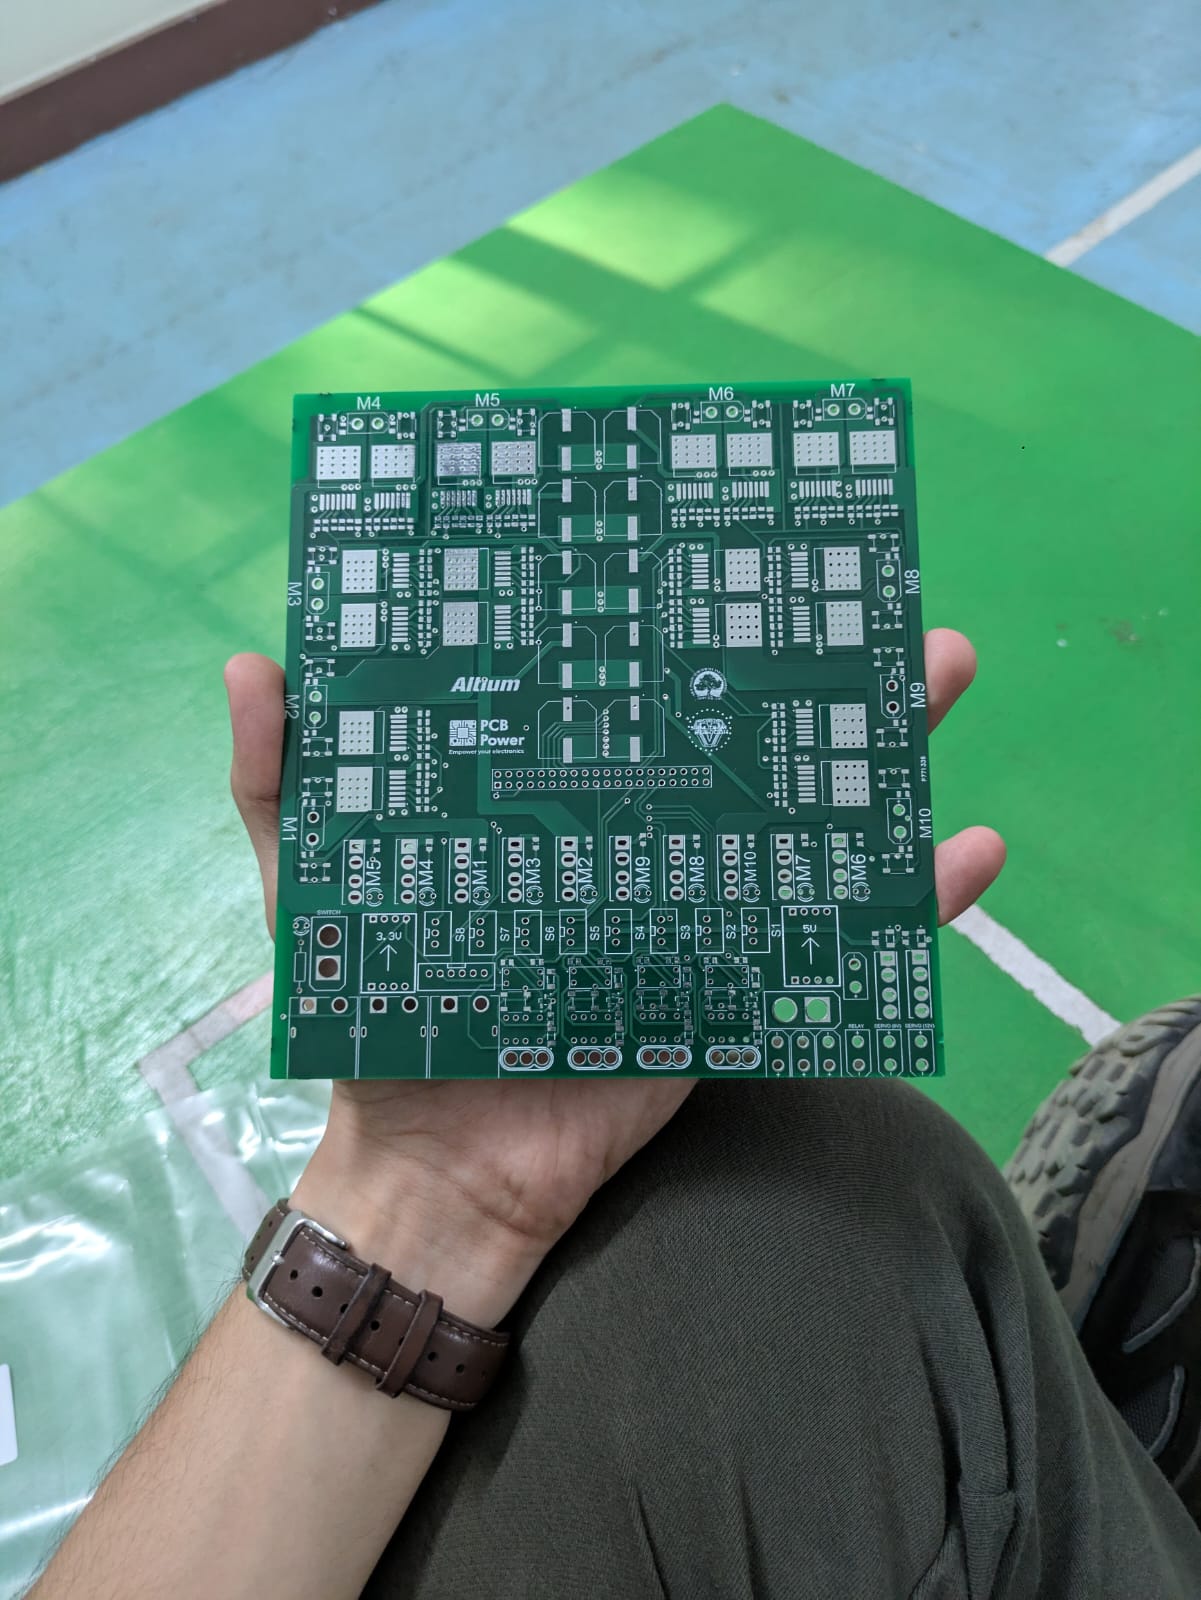
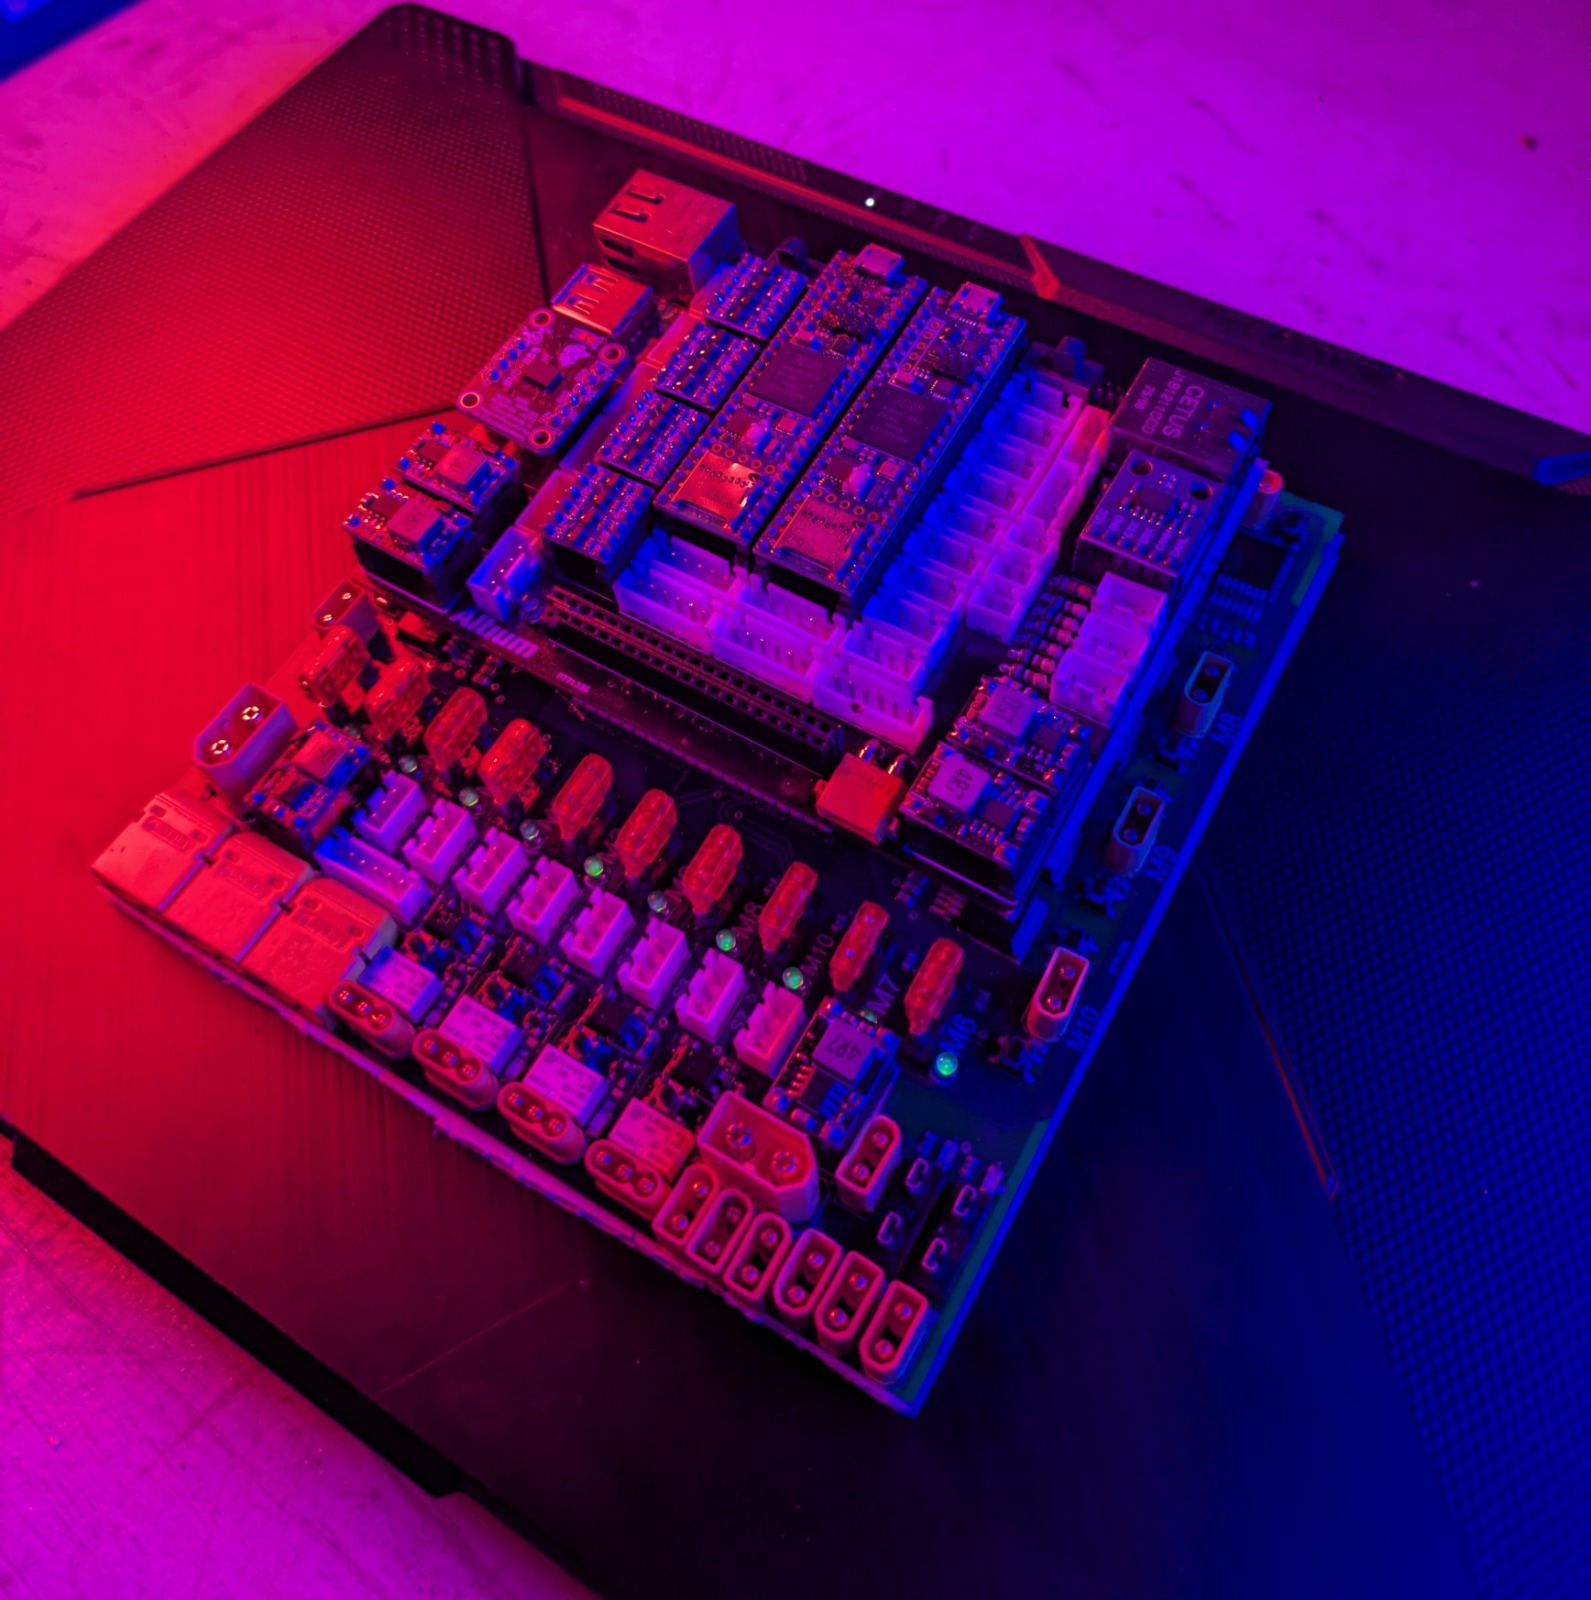
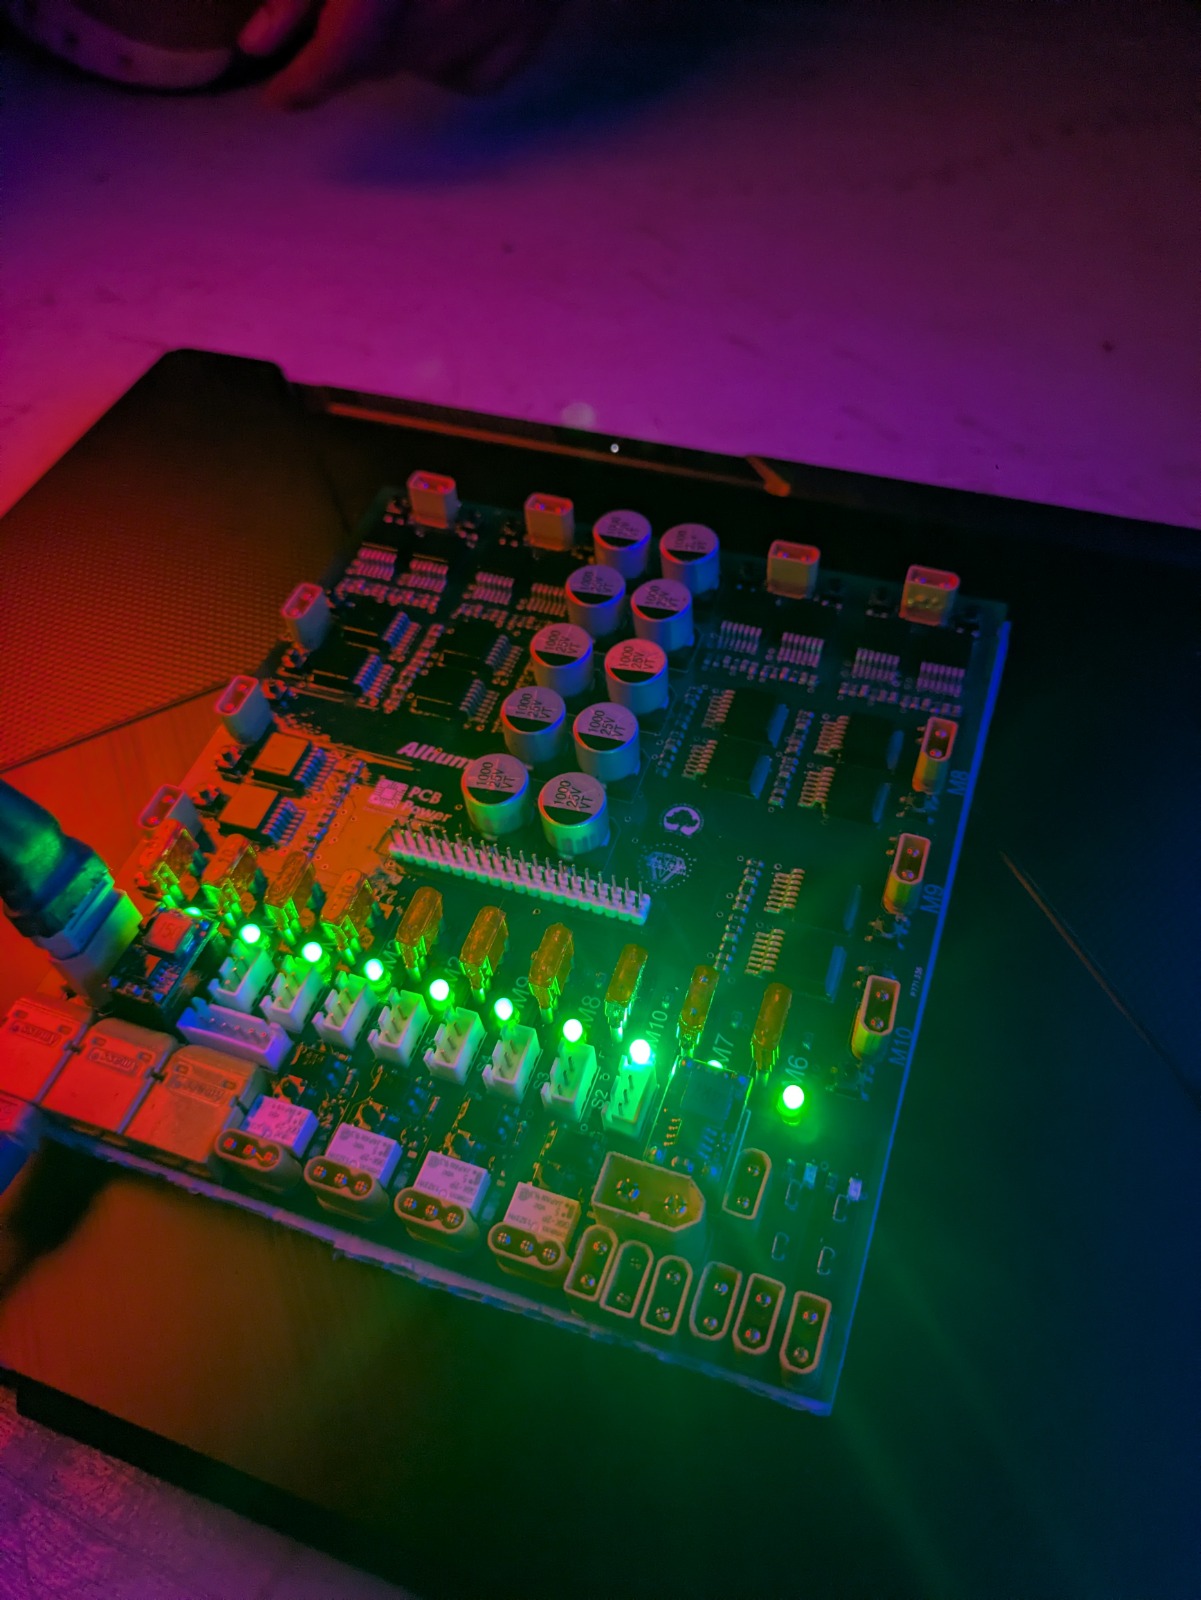
My first 4-layer PCB, working on first bring-up. A fixed Actuator Board plus a detachable, shield-style Interface Board, so the controller can be swapped without touching the power layer.
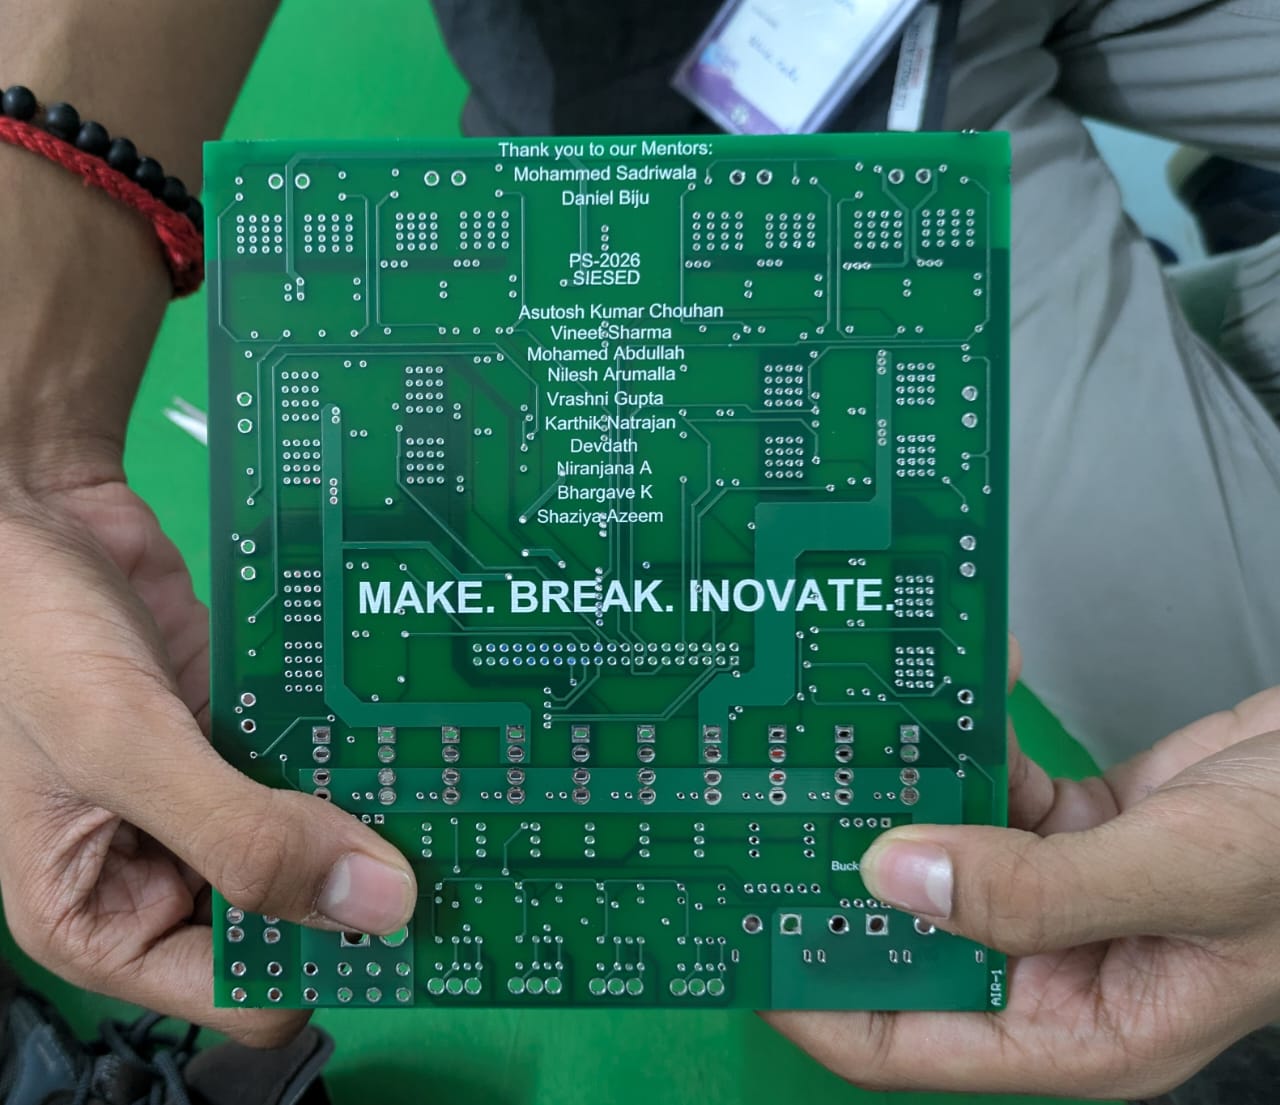
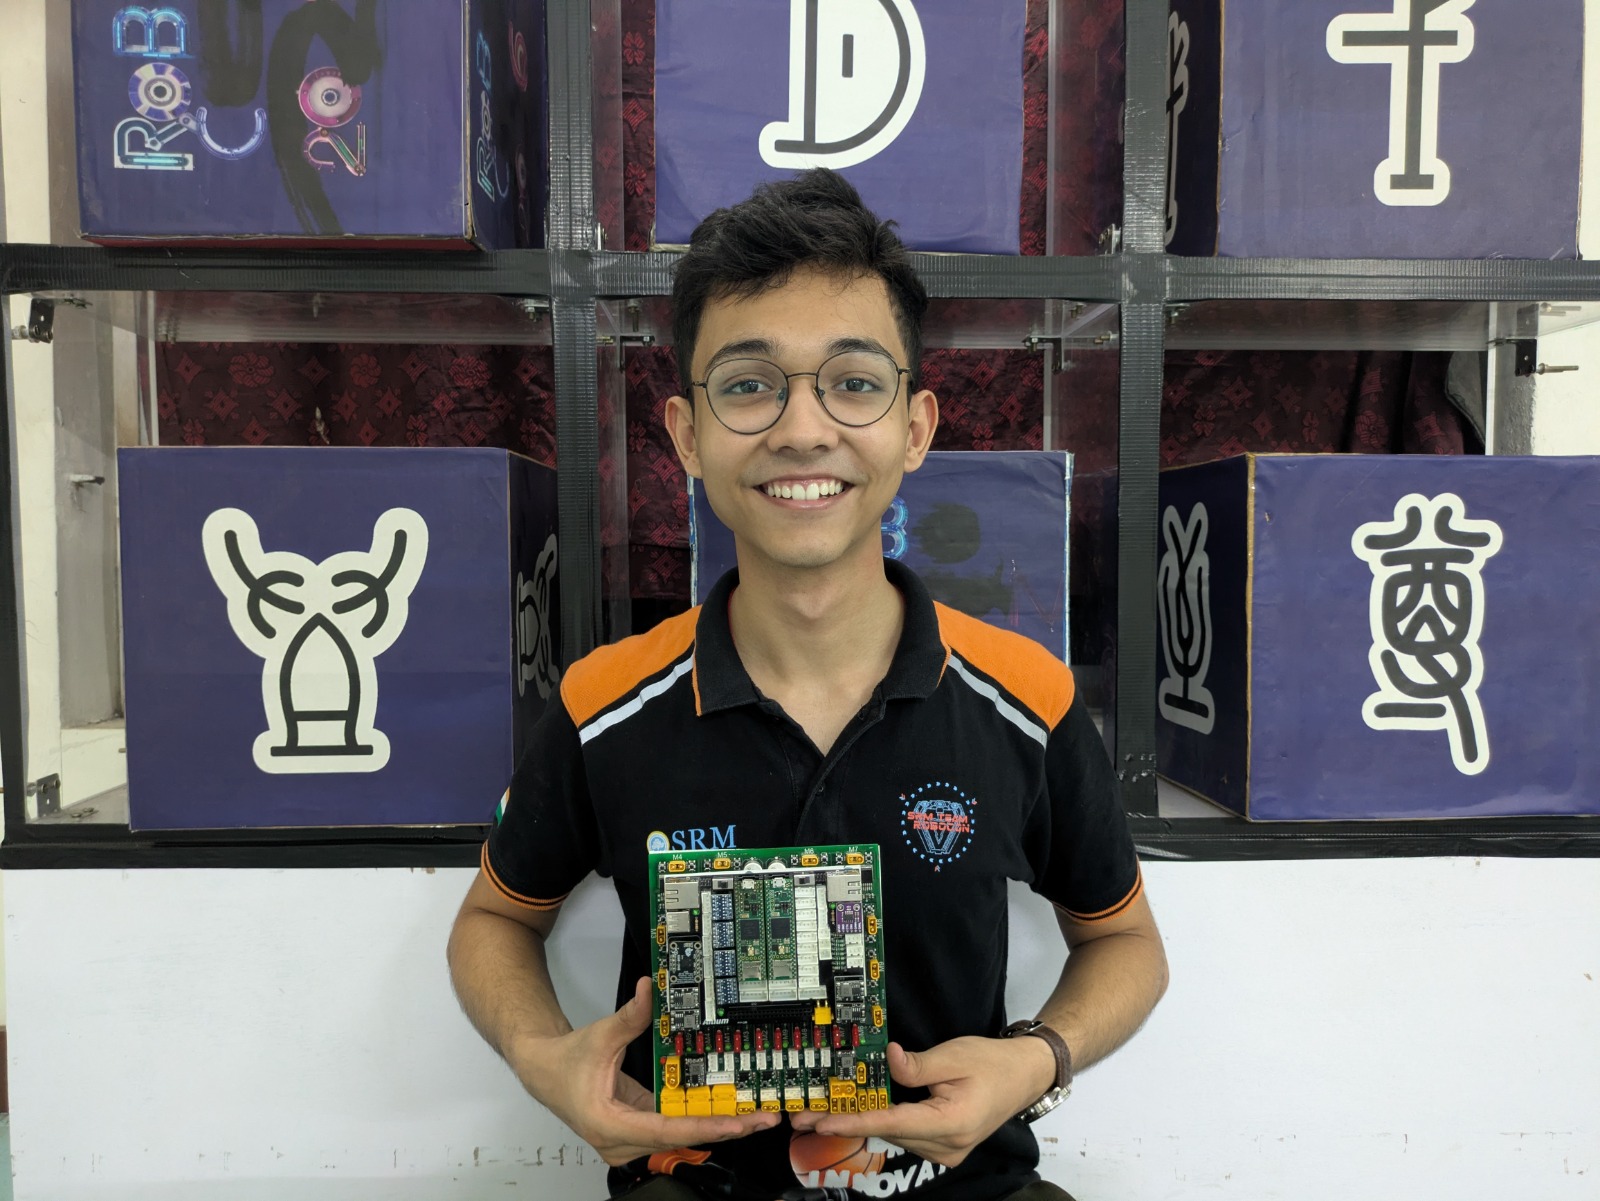
★ Contributed to the team's AIR 5 finish — DD Robocon 2026, IIT Delhi
// Interactive 3D PCB — Actuator Board
// Drag to rotate · scroll to zoom
Open Full Screen ↗
// Design Highlights
  • Designed the 4-layer PCB end-to-end in Altium — schematic, layout, manufacturing files
  • Architected a modular two-board system with a swappable MCU interface
  • Routed 10 motor drivers, servo interfaces and pneumatic relay control with on-board power regulation
  • Hand-soldered every SMD part in-house
// Stack
Altium4-Layer PCBMotor Drivers Servo · PneumaticPower RegulationSMD Soldering